Why does my VEX auton miss?
It worked three times in a row, then missed at the tournament. Almost every team hits this. The good news: the causes are known, and each one has a fix.
The usual suspects
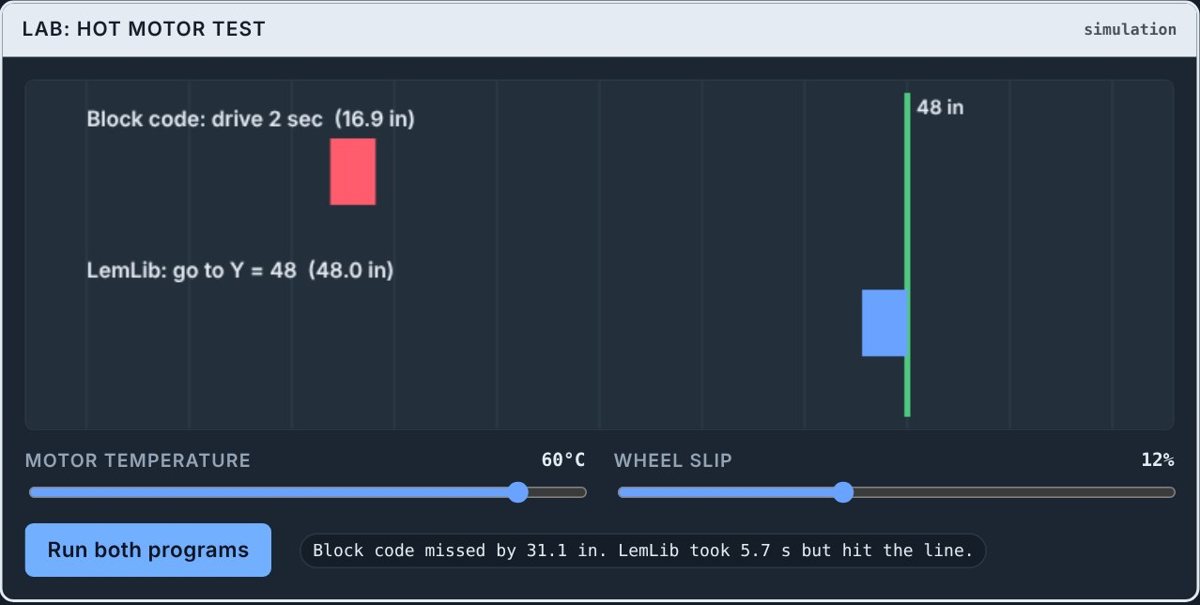
- 🔥Warm motorsHot motors are weaker, so the same code drives shorter.
- 🔋Battery levelA low battery slows everything down.
- 🛞Wheel slipFast starts and stops make wheels skid.
- 📐Start positionOne degree off at the start is inches off later.
- ➕Errors add upEach move starts from the last mistake.
The fixes, from quickest to best
- Line up the same way every time. Use a tile seam or a jig, and mark it in your notebook.
- Turn with the inertial sensor, not by motor degrees.
- Slow down the starts and stops (or tune them with PID) so wheels don't slip.
- Add odometry. Tracking wheels let the robot know where it really is and drive to a point, so small errors don't pile up. LemLib and JAR-Template both do this.
- Tune one number at a time, and write each change in the engineering notebook.
Test it like a scientist
| What I changed | Why | What happened |
|---|---|---|
| First turn 90° → 85° | Robot hit the wall 3 of 3 runs | Cleared the wall 3 of 3. Still 2" short at goal. |
| Drive kP 10 → 12 | Stopped short on long drives | Reaches the goal. Small wobble; try kD next. |
| Added tracking wheel | Wheels slipped on fast starts | Ends within 1" every run. |
Run the auton five times. Mark where it ends each time. If the misses are all in the same direction, it's a setting you can tune. If they're all over the place, it's slip, start position or a loose part.
Questions people ask
Why is my VEX autonomous inconsistent?
Usually warm motors, battery level, wheel slip, a slightly different start position, or small errors adding up between moves.
How do I make my VEX auton more accurate?
Line up the same way every time, turn with the inertial sensor, smooth out starts and stops, and add odometry with tracking wheels using LemLib or JAR-Template.
Do I need odometry for a good auton?
Not for a short one, but for longer routines and skills runs odometry is the biggest single improvement.
Try it free. The first autonomy.school missions run in your browser. No sign-up, nothing to install, and there's a virtual robot if yours is at school or the lab.
Start the free missions